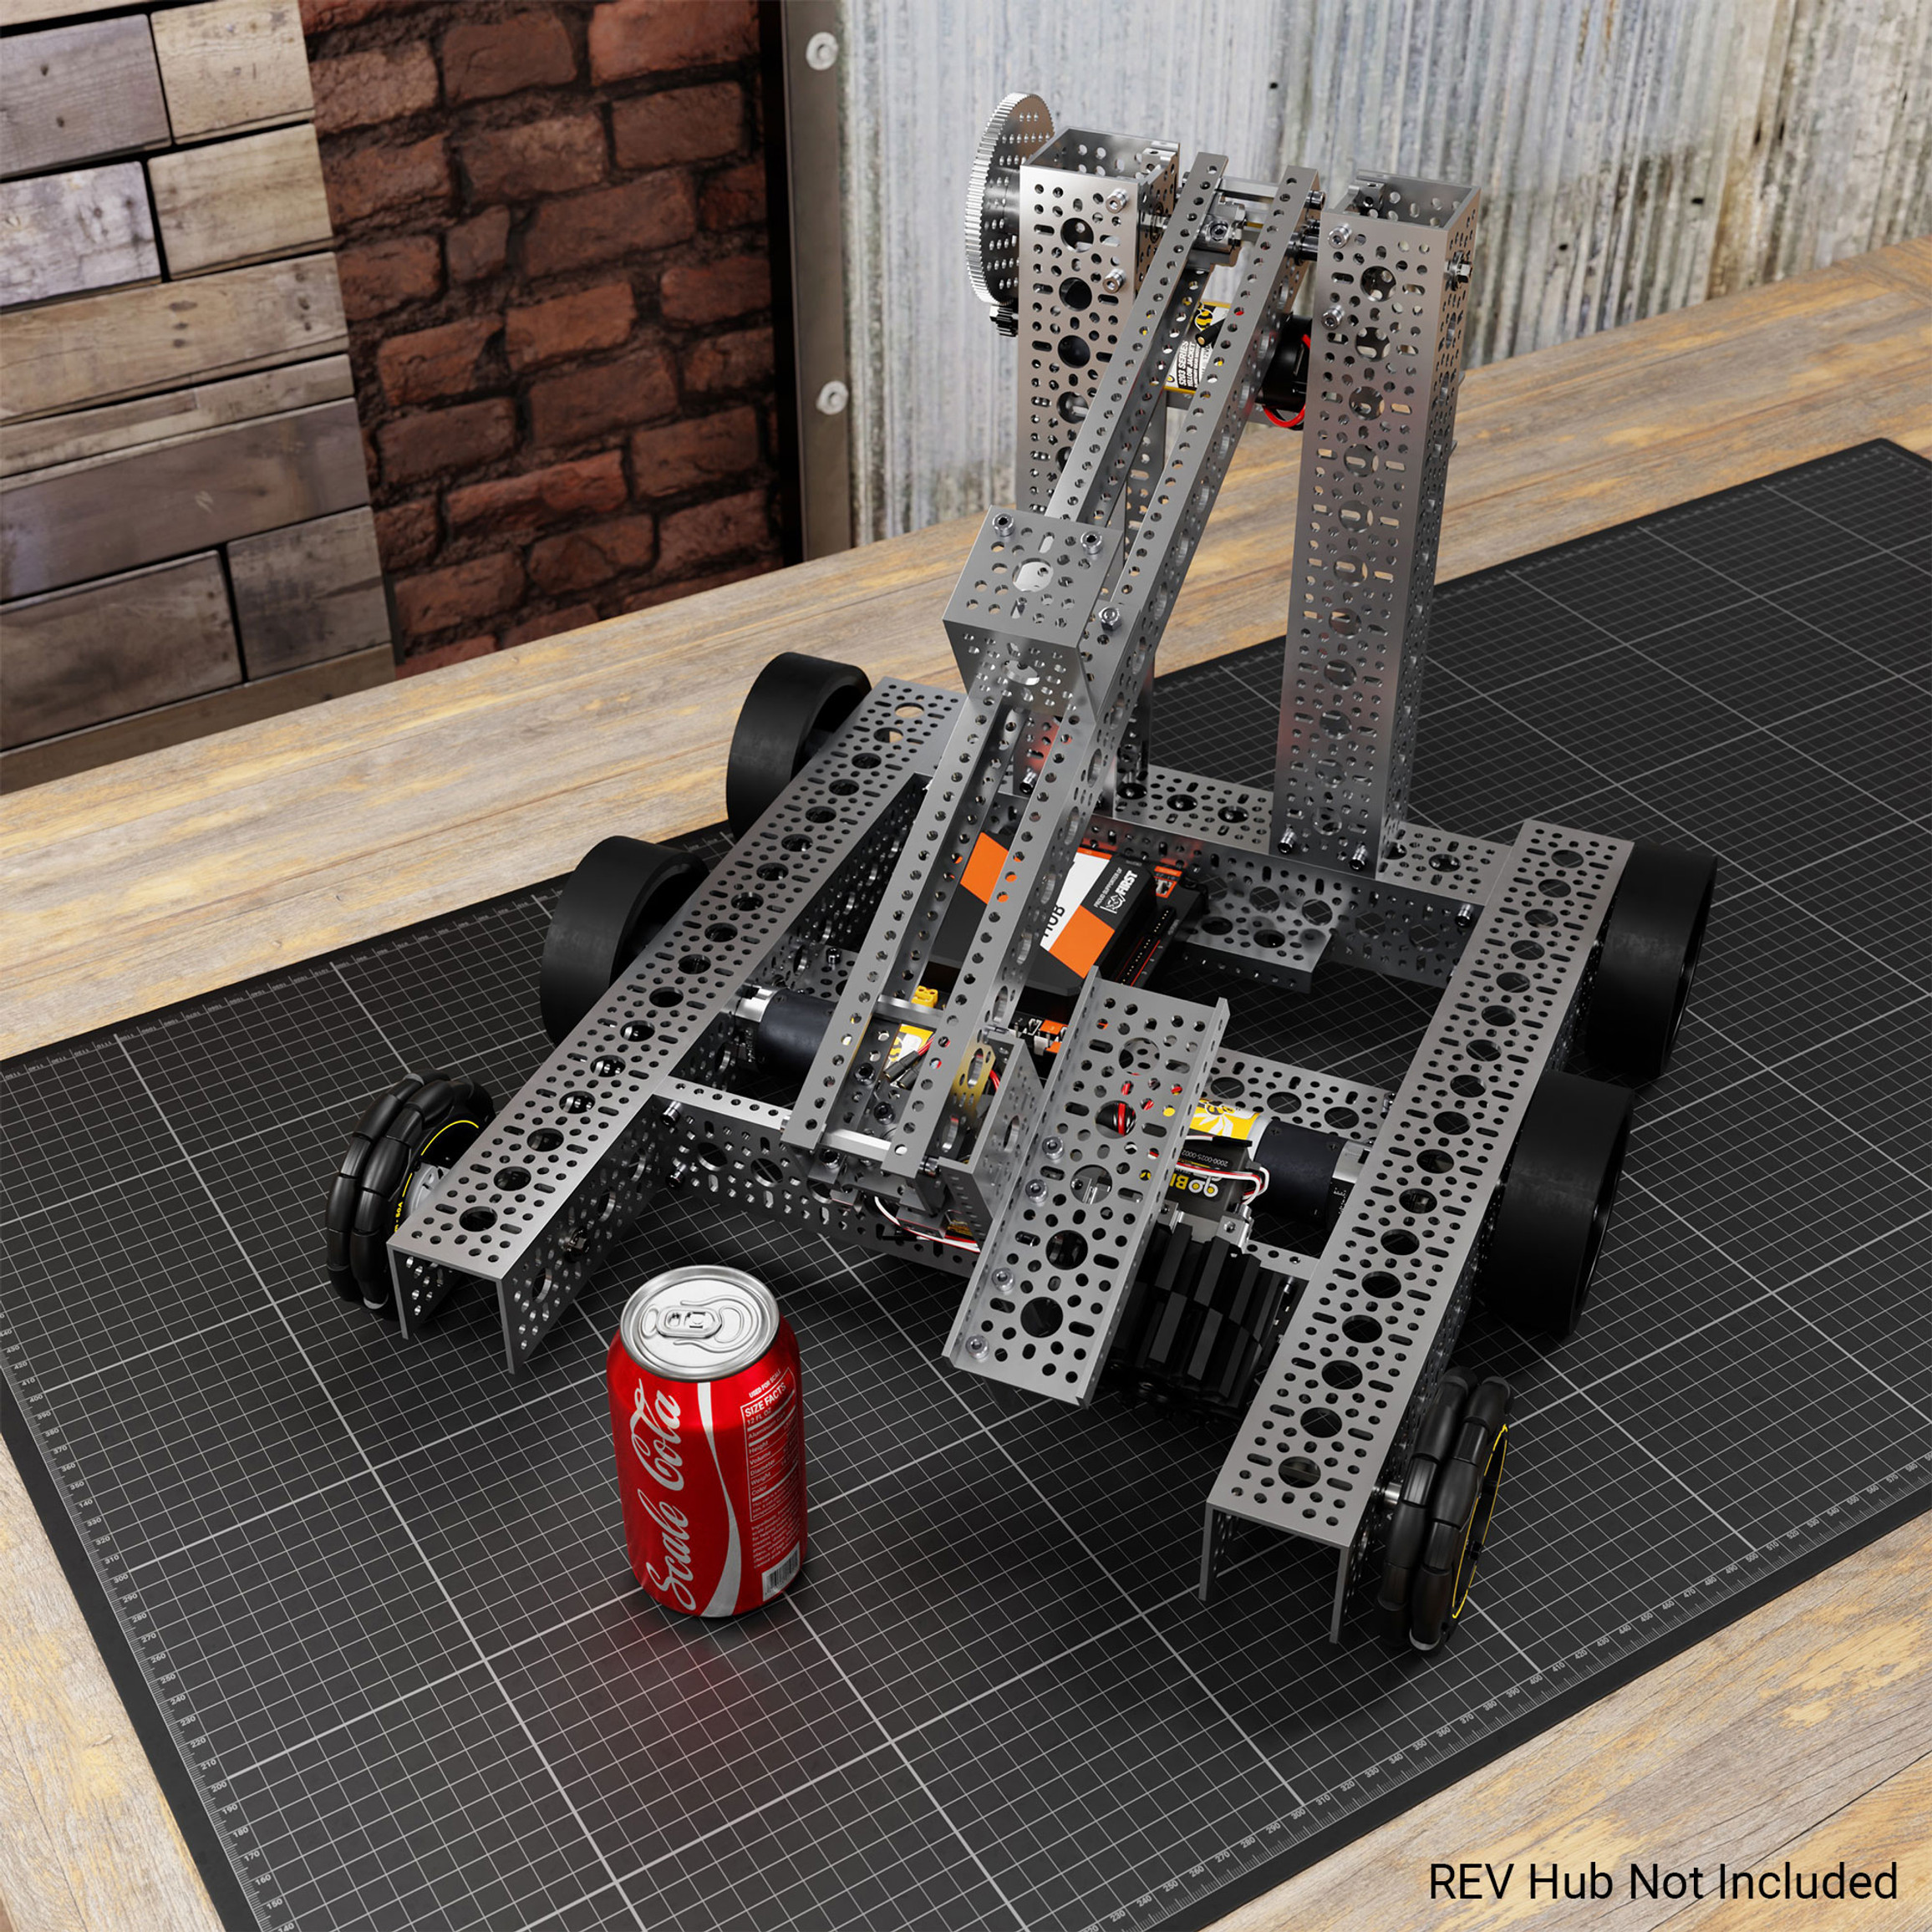
Draft: Develop a remotely controlled robot that uses an extending arm and claw to pick up, move, and place a payload in a simulated exploration environment.
Available FTC parts and tools.
Time remaining before PDR.
Available motor and battery capacity.
Controlled driving and stopping.
Controlled arm extension.
Claw opening and closing.
Payload pickup and placement.
Stability while handling the payload..
Our first idea was an elevator-style lift to raise and lower the claw. We decided it would take up too much space and be too difficult to build with our available time and parts, so we started considering an extending arm instead.
Our initial design choices were based on our experience building and working on FRC robots, particularly with mechanisms, assembly, and control systems. External research has not yet been completed.
After reconsidering the elevator lift, we chose to move forward with an extending arm and claw. We felt this would fit the robot better and be more manageable to build using our available parts and FRC experience.

A simpler arm that pivots up and down but cannot extend, limiting its reach.
Reference images; not our prototype.
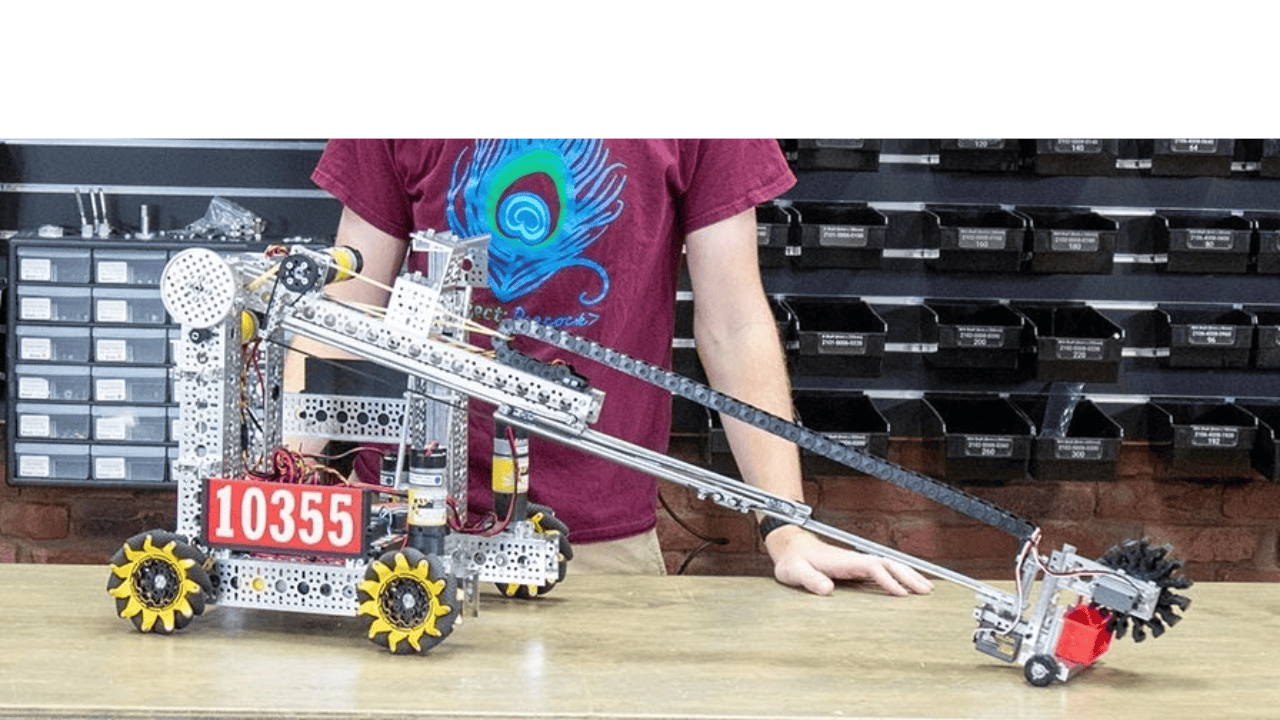
The arm pivots up and down and extends outward, with a claw at the end for gripping and placing the payload.
Reference image; not our prototype.
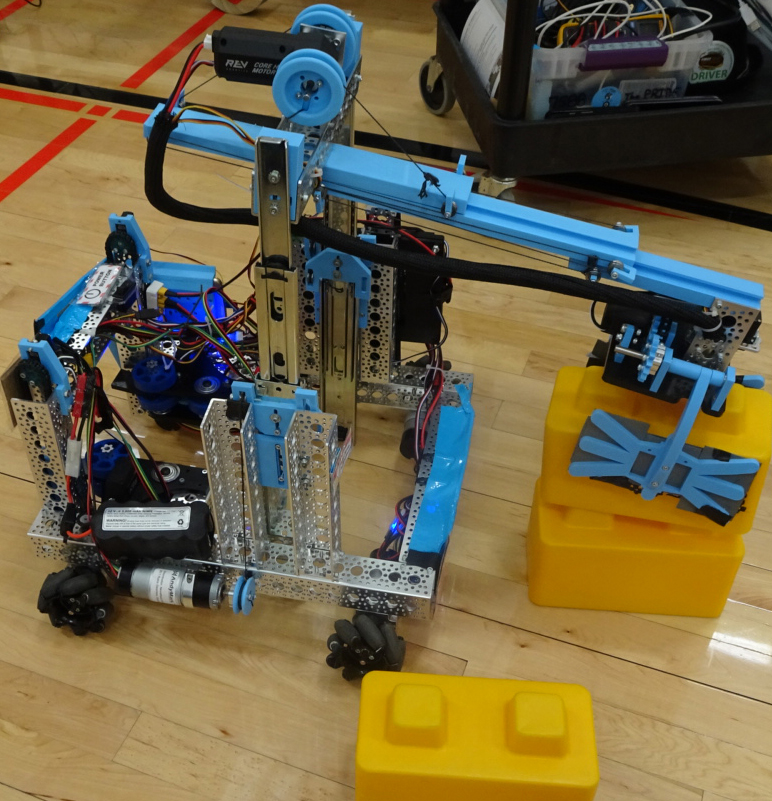
A vertical lift raises and lowers the claw.
Reference images; not our prototype.
Team judgment: 1 = poor, 5 = strong. These are design estimates, not test results.
| Criterion | A | B | C |
|---|---|---|---|
| Meets assigned task | 3 | 5 | 4 |
| Build feasibility | 4 | 4 | 3 |
| Stability | 3 | 3 | 3 |
| Uses available parts | 4 | 4 | 2 |
| Total / 20 | 14 | 16 | 12 |